Equipment & models
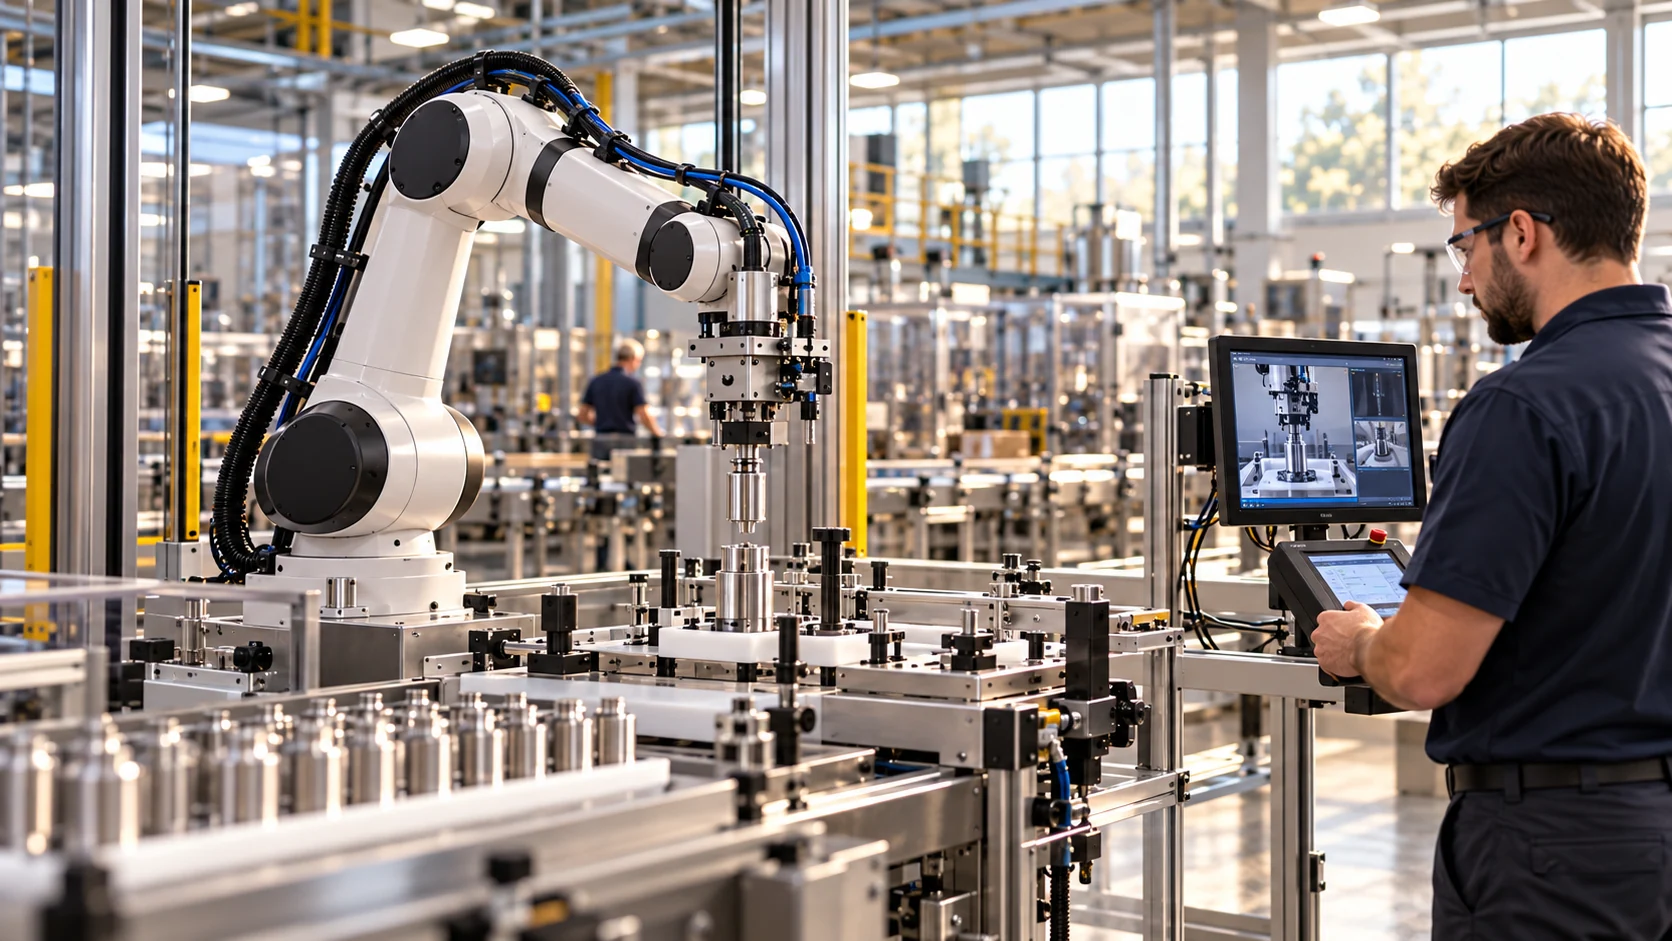
Robot task development cell
MFG-RB01 · original concept model · rotate, inspect named components and follow the linked training drafts.
Live browser 3D viewer
Inspect the equipment. Follow the decision.
Loading the local GLB…
Select a component in the model or picker. Drag to orbit; pinch or scroll to zoom.
Exploded layout is an illustration, not a disassembly sequence. Scene units and motions are not accepted engineering dimensions or kinematics.
A model with an explicit source boundary.
What you can explore
Explain a bounded pick/place task, gripper relationship and human review before hardware qualification.
Static illustrative robot, movable jaw/lift concepts only. No IK solver, collision validation, robot code or autonomous execution.
What the native task needs
Robot make/controller and limits; gripper/workpiece CAD; sensing; safeguarded cell design; integrator-approved test plan.
Read source and version notesMove from the model to the product.
Use the parent tools with permitted sources and a qualified reviewer. This website has no native lesson or operational guidance session.