Context
01 / Establish the source
Robot make/controller and limits; gripper/workpiece CAD; sensing; safeguarded cell design; integrator-approved test plan.
Explore
Manufacturing solution
Explain a bounded pick/place task, gripper relationship and human review before hardware qualification.
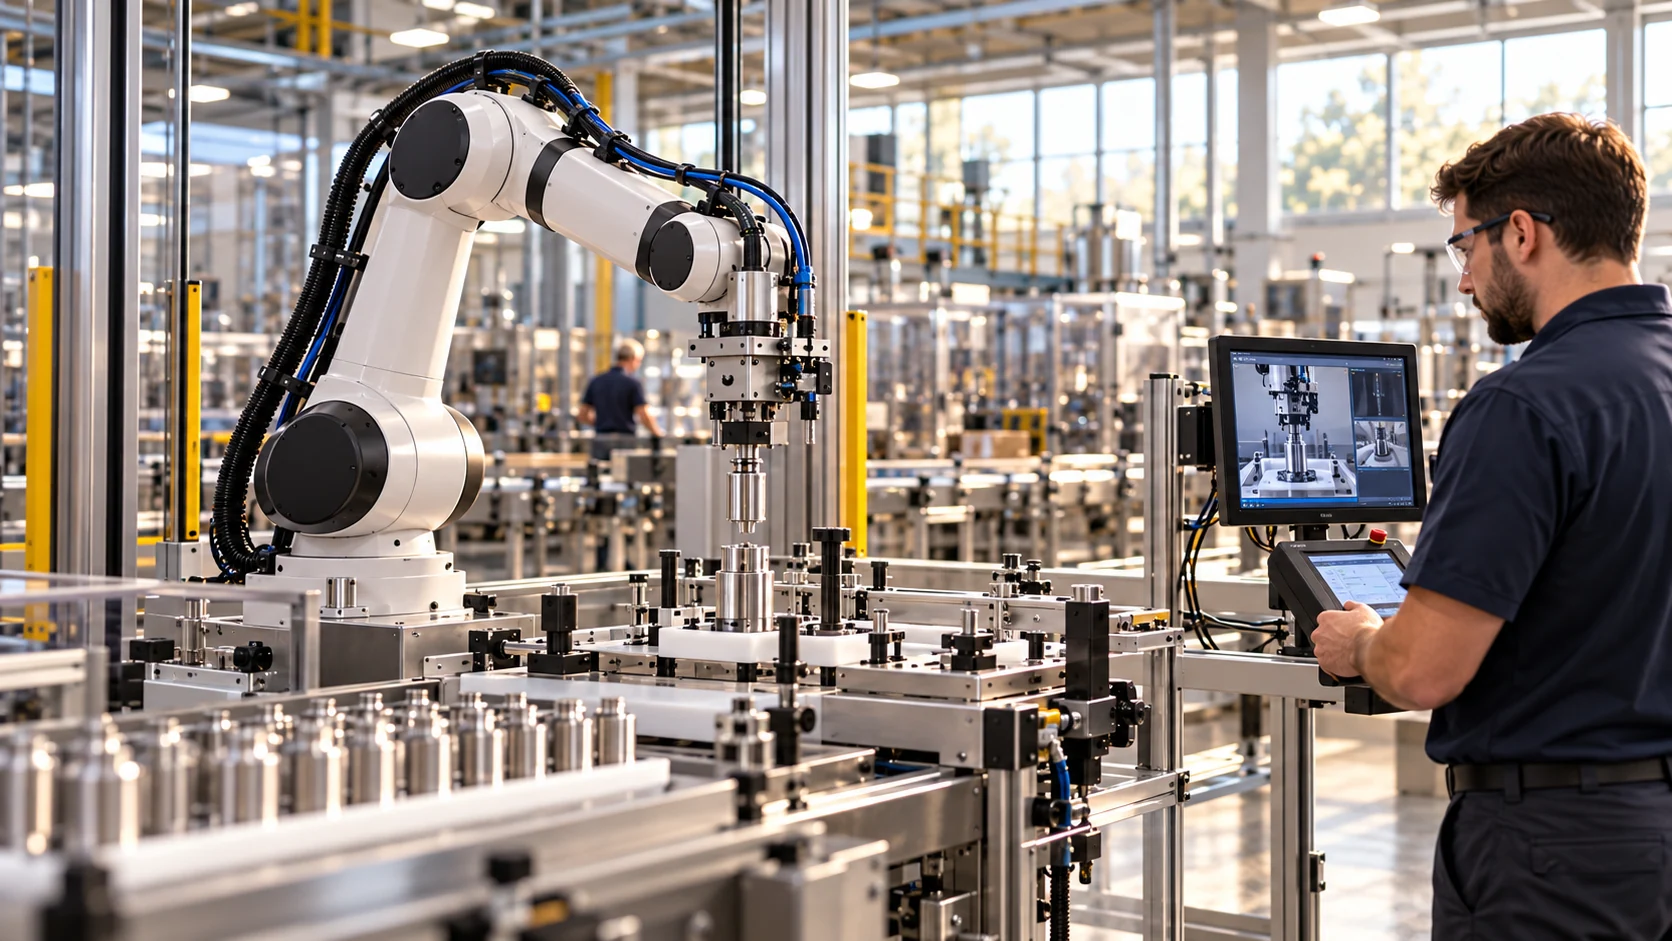
Automation engineering, robot integrators and training
Explain a bounded pick/place task, gripper relationship and human review before hardware qualification.
A task decomposition, explicit scene limits and a hardware-specific validation request.
Task ambiguity, omitted boundary conditions and unverified transfer assumptions.
Context
Robot make/controller and limits; gripper/workpiece CAD; sensing; safeguarded cell design; integrator-approved test plan.
ExplorePractice
Explain a bounded pick/place task, gripper relationship and human review before hardware qualification.
ExploreEvidence & release
A task decomposition, explicit scene limits and a hardware-specific validation request.
Explore
MFG-RB01 · original concept GLB
Explain a bounded pick/place task, gripper relationship and human review before hardware qualification.
ExploreStatic illustrative robot, movable jaw/lift concepts only. No IK solver, collision validation, robot code or autonomous execution.
Three connected procedures
Context: permitted sources and asset identity. Practice: meaningful decisions and recovery. Execution: a separately reviewed supervised task. Evidence: observations, measurements and uncertainty. Release: a qualified human approves any reuse.